Tethered Mobile Robot
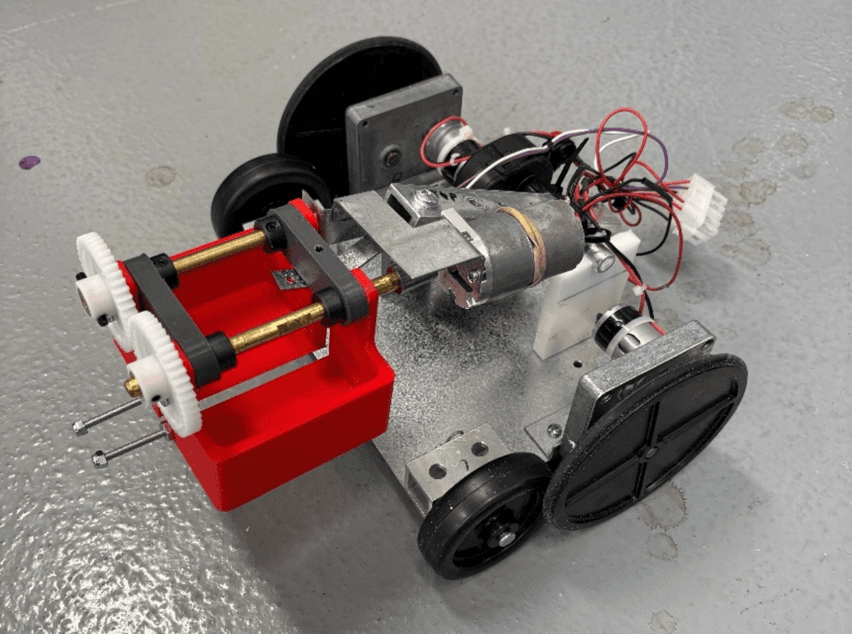
Bryce and I built a tethered robot to pick up and move objects around a competition course. We fabricated the sheet-metal structure, fitted the wheels and motors, and built the lifting and gripping mechanisms.
My role
I focused on the lifting arm, motor selection, and wiring. Bryce focused on the claw and designed the final 3D-printed jaws. We both worked on the CAD assembly, fabrication, and testing.
Designing the arm
I modeled the lifting arm, bucket support bracket, and a custom shaft collar in SolidWorks. I also worked on assembly layouts and put together the bill of materials.
I estimated the torque needed to lift the 0.25 kg payload, then selected and tested a worm gearmotor. It held the arm in position while we adjusted the claw to pick up objects.
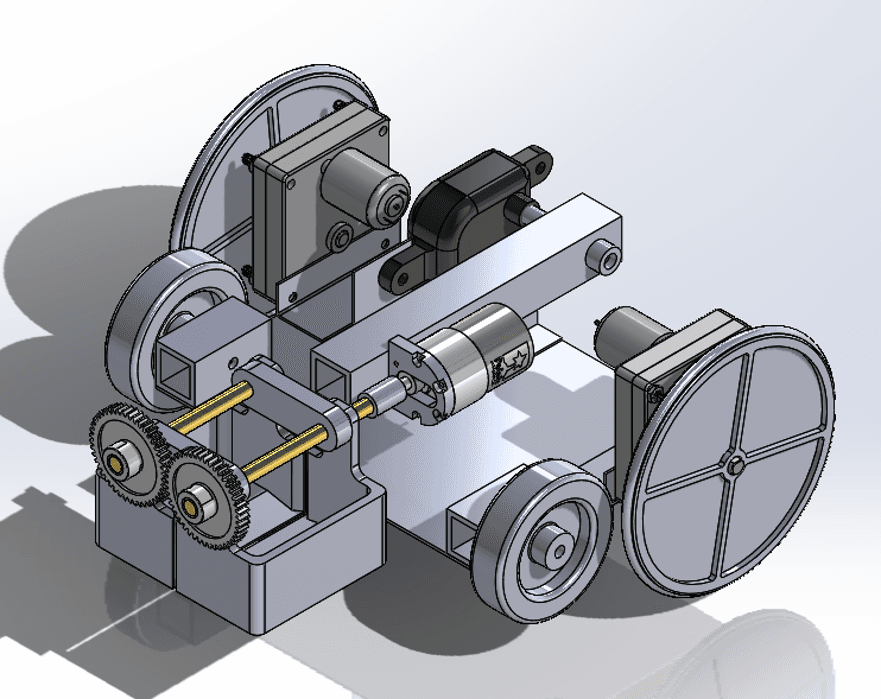
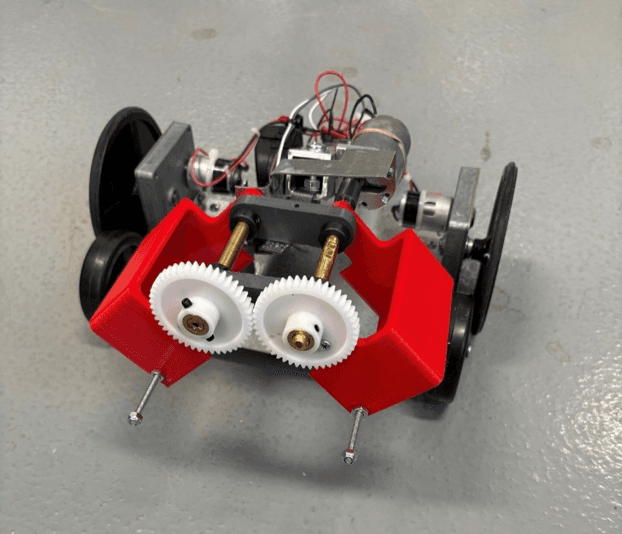
Building and testing
I made versions of the base plate, brackets, and arm using sheet-metal tools and a drill press. I also installed the lifting motor and wired the motors to the controller with crimped connections.
During testing, I corrected gear-alignment problems in an earlier version of the gripping mechanism. We continued adjusting the assembly as the claw design changed.
The result
The robot picked up and moved several objects, including the 0.25 kg dumbbell. It handled rigid objects better than clothing, which the claw struggled to grip.